 MIT OpenCourseWare
Risk Aware and Robust Nonlinear Planning
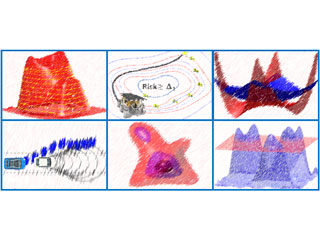
In this course, Dr. Ashkan Jasour addresses advanced probabilistic and robust optimization-based techniques for control and safety verification of nonlinear dynamical systems in the presence of uncertainties. Specifically, we will learn how to leverage rigorous mathematical tools, such as the theor…
- MIT
- Self-paced
- Free course
- Advanced

.jpg)